Often, when solving real problems, you must pursue a path to its
logical conclusion. If this conclusion does not give the answer you were
looking for, you must choose an alternate path. For
instance, you might have played maze games when you were a child. One sure way
to find the end of the maze was to turn left at every fork in the maze until
you hit a dead end. At that point you would back up to the last fork, and try
the right-hand path, once again turning left at each branch encountered. By
methodically trying each alternate path, you would eventually find the right
path and win the game.
Visual Prolog
uses this same backing-up-and-trying-again method, called backtracking, to find a solution to a given problem. As Visual Prolog begins to look for a solution
to a problem (or goal), it might have to decide between two possible cases. It
sets a marker at the branching spot (known as a backtracking point) and selects the
first subgoal to pursue. If that subgoal fails (equivalent to reaching a dead
end), Visual Prolog will backtrack to
the back-tracking point and try an alternate subgoal.
Here is a simple
example:
/* Program ch04e02.pro */
/* 현실
문제를 풀때 논리적인 결론에 이르는 path를
찾아야 한다. 결론이 찾는 답을 주지 못할 때 다른 path를
선택하게 된다.prolog는 주어진 goal에 만족하는 모든 답을 찾아야 한다.
이때 goal을 만족시킬 경우는 다른 답을 찾기 위해, 만족시키지 못할
경우는 답을 찾기위해 database를 처음부터 탐색해 나간다. 이를 backtracking이라하는 backing-up-and-trying-again method 이다. goal에
대한 하나의 solution을 찾기 시작하면서 branching spot ( = backtracking
point )을 marker로서 표시하고 first subgoal이 fail 하면 그 point로
되돌아가 다른 subgoal을 try 한다 */
PREDICATES
nondeterm likes(symbol,symbol)
tastes(symbol,symbol)
nondeterm food(symbol)
CLAUSES
likes(bill,X):- /* What 은 variable
X에 unified , rule 의 head가
matching됨*/
food(X),
/* rule의 body에서 첫번째 subgoal 호출(call)
*/
tastes(X,good).
/* tastes(brussels_sprouts,good)를 찾기위해 top으로부터
탐색. call이 fail하고 자동적으로 backtracking
수행된다 */
tastes(pizza,good).
/* 첫번째 subgoal 의 만족여부를 위해 top에서부터 search */
tastes(brussels_sprouts,bad).
food(brussels_sprouts).
/* call된 fact 다음에 backtracking point를 둔다, X 는 brussels_sprouts
로 bind */
food(pizza).
/* 한번
bind된 변수는 backtracking에 의해서만 free 하게 된다. X는 pizza에
bind 되고 tastes(pizza,good) 가 새로이 호출 (call) 된다. 다시 top으로부터
탐색이 되고 match가 이루어져 goal은 성공적으로
리턴된다. likes rule에서 What은 X와 unify되고
X는 값 pizza와 bind 되었기 때문에 What 은 값 pizza 와 새로이 bind
되어 답을 낸다 */
GOAL
likes(bill, What).
출력
What
= pizza
1 solution
/* rule의
head부 match를 위한 search는 program의 top에서부터 시작한다
새로운
call이 있을 때 그에 match되는 것도 top에서부터 search한다
하나의
call이 성공적으로 match 되면 다른 subgoal을 차례로 수행한다
clause에서
한번 bind된 변수는 backtracking에 의해서만 free 하게 된다 */
This small program is made up of two sets of
facts and one rule. The rule, represented by the relationship likes,
simply states that Bill likes good-tasting food.
To see how backtracking works, give the program
the following goal to solve:
likes(bill, What).
|
When Prolog begins an attempt to satisfy a goal,
it starts at the top of the program in search of a match.
|
In this case, it will begin the search for
a solution by looking from the top for a match to the subgoal likes(bill, What).
It finds a match with the first clause in the
program, and the variable What is
unified with the variable X. Matching
with the head of the rule causes Visual
Prolog to attempt to satisfy that rule. In doing so, it moves on to the
body of the rule, and calls the first subgoal located there: food(X).
When a new call is made, a search for a match to
that call also begins at the top of the program.
|
In the search to satisfy the first subgoal,
Visual Prolog starts at the top,
attempting a match with each fact or head of a rule encountered as processing
goes down into the program.
It finds a match with the call at the first fact
representing the food relationship. Here, the variable X is bound to the value brussels_sprouts.
Since there is more than one possible answer to the call food(X), Visual Prolog sets a backtracking point
next to the fact food(brussels_sprouts). This backtracking point keeps track of where Prolog will start
searching for the next possible match for food(X).
When a call has found a successful match, the
call is said to succeed, and the next subgoal in turn may be tried.
|
With X bound to brussels_sprouts, the next call made is
tastes(brussels_sprouts, good)
and Visual
Prolog begins a search to attempt to satisfy this call, again starting
from the top of the program. Since no clause is found to match, the call fails
and Visual Prolog kicks in its
automatic backtracking mechanism. When backtracking begins, Prolog retreats to
the last backtracking point set. In this case, Prolog returns to the fact food(brussels_sprouts).
Once a variable has been bound in a clause, the
only way to free that binding is through backtracking.
|
When Prolog retreats to a backtracking
point, it frees all the variables set after that point, and sets out to find
another solution to the original call.
The call was food(X), so the
binding of brussels_sprouts for X is released. Prolog
now tries to resolve this call, beginning from the place where it left off. It
finds a match with the fact food(pizza)] and returns, this time with the variable X bound to the value pizza.
Prolog now moves on to the next subgoal in the
rule, with the new variable binding. A new call is made, tastes(pizza, good)], and the search begins at the top of the program. This time, a match
is found and the goal returns successfully.
Since the variable What in the goal is unified with the variable X in the likes rule, and the variable X is bound to the value pizza, the variable What is now bound to the value pizza
and Visual Prolog reports the
solution
What=pizza
1 Solution
As we've described earlier, with the aid of
backtracking, Visual Prolog will not
only find the first solution to a problem, but is actually capable of finding
all possible solutions.
Consider Program 3, which contains facts about
the names and ages of some players in a racquet club.
/* Program ch04e03.pro */
/* prolog는 문제에 대한 하나의 solution만을 찾는 것이 아니고
가능한 모든 solution들을 전부 찾는다. 그것이 backtracking
의 잇점이다.*/
DOMAINS
child = symbol
age =
integer
PREDICATES
nondeterm player(child,
age)
CLAUSES
player(peter,9).
player(paul,10).
player(chris,9).
player(susan,9).
GOAL
/* compound goal */
player(Person1,
9),
player(Person2,
9),
Person1
<> Person2.
/* 나이가
9살이면서 다른 사람인 Person1 과 Person2을 찾아라 */
출력
Person1
= peter, Person2 = chris
Person1
= peter, Person2 = susan
Person1
= chris, Person2 = peter
Person1
= chris, Person2 = susan
Person1
= susan, Person2 = peter
Person1
= susan, Person2 = chris
6 solutions
You'll use Visual
Prolog to arrange a ping-pong tournament between the nine-year-olds in a
racquet club. There will be two games for each pair of club players. Your aim
is to find all possible pairs of club players who are nine years old. This can
be achieved with the compound goal:
player(Person1, 9),
player(Person2, 9),
Person1 <> Person2.
In natural language: Find Person1 (age 9) and Person2
(age 9) so that Person1 is different
from Person2.
Visual Prolog will try to find a solution
to the first subgoal player(Person1,
9) and continue to the next subgoal only after the
first subgoal is reached. The first subgoal is satisfied by matching Person1 with peter. Now Visual Prolog
can attempt to satisfy the next subgoal:
player(Person2, 9)
by also matching Person2 with peter. Now
Prolog comes to the third and final subgoal
Person1 <> Person2
Since Person1 and Person2 are both bound to peter,
this subgoal fails. Because of this, Visual
Prolog backtracks to the previous subgoal, and searches for another
solution to the second subgoal:
player(Person2, 9)
This subgoal is fulfilled by matching Person2 with chris.
Now, the third
subgoal:
Person1 <> Person2
can succeed, since peter and chris are
different. Here, the entire goal is satisfied by creating a tournament between
the two players, chris and peter.
However, since Visual Prolog
must find all possible solutions to a goal, it backtracks to the previous
goal--hoping to succeed again. Since
player(Person2, 9)
can also be satisfied by taking Person2 to be susan, Visual Prolog
tries the third subgoal once again. It succeeds (since peter and susan are
different), so another solution to the entire goal has been found.
Searching for more
solutions, Visual Prolog once again
backtracks to the second subgoal, but all possibilities for this subgoal have
been exhausted. Because of this, backtracking now continues back to the first
subgoal. This can be satisfied again by matching Person1 with chris. The
second subgoal now succeeds by matching Person2
with peter, so the third subgoal is
satisfied, again fulfilling the entire goal. Here, another tournament has been
scheduled, this time between chris
and peter.
Searching for yet
another solution to the goal, Visual Prolog
backtracks to the second subgoal in the rule. Here, Person2 is matched to chris
and again the third subgoal is tried with these bindings. The third subgoal
fails, since Person1 and Person2 are equal, so backtracking regresses
to the second subgoal in search of another solution. Person2 is now matched with susan,
and the third subgoal succeeds, providing another tournament for the racket
club (chris vs. susan).
Once again,
searching for all solutions, Prolog backtracks to the second subgoal, but this
time without success. When the second subgoal fails, backtracking goes back to
the first subgoal, this time finding a match for Person1 with susan. In an
attempt to fulfill the second subgoal, Prolog matches Person2 with peter, and
subsequently the third subgoal succeeds with these bindings. A fifth tournament
has been scheduled for the players.
Backtracking again
goes to the second subgoal, where Person2
is matched with chris. A sixth
solution is found for the racquet club, producing a full set of tournaments.
The final solution
tried is with both Person1 and Person2 bound to susan. Since this causes the final subgoal to fail, Visual Prolog must backtrack to the second
subgoal, but there are no new possibilities. Visual
Prolog then backtracks to the first subgoal, but the possibilities for Person1 have also been exhausted. No
more solutions can be found for the goal, so the program terminates.
Type in this compound goal for the program:
player(Person1, 9),
player(Person2, 9),
Person1 <> Person2.
Verify that Visual
Prolog responds with
Person1=peter, Person2=chris
Person1=peter, Person2=susan
Person1=chris, Person2=peter
Person1=chris, Person2=susan
Person1=susan, Person2=peter
Person1=susan, Person2=chris
6 Solutions
Notice how backtracking might cause Visual Prolog to come up with redundant
solutions. In this example, Visual Prolog
does not distinguish that Person1
= peter is the same thing as Person2 = peter.
We will show you later in this chapter how to control the search Visual Prolog generates.
Exercise in Backtracking
Using Program 3, decide what Visual Prolog will reply to the following
goal:
player(Person1, 9), player(Person2, 10).
Check your answer by typing in the exercise and
the given goal when you run the program.
A Detailed Look at Backtracking
With this simple example under your belt, you
can take a more detailed look at how Visual
Prolog's backtracking mechanism works. Start by looking at Program 4 in
light of the following goal, which consists of two subgoals:
likes(X, wine) , likes(X, books)
When evaluating the
goal, Visual Prolog notes which
subgoals have been satisfied and which have not. This search can be represented
by a goal tree:
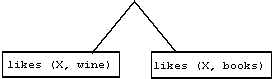
Before the goal evaluation begins, the goal tree
consists of two unsatisfied subgoals. In the following goal tree diagrams, a
subgoal satisfied in the goal tree is marked with an underline, and the
corresponding clause is shown beneath that subgoal.
/* Program
ch04e04.pro
*/
backtracking
의 4가지 기본원칙
1. subgoal은
위에서 아래로 순서대로 만족되어야 한다
2. Predicate
clause는 프로그램에 나타나는 순서대로 위에서 아래로 test되어야 한다
3. subgoal이
rule의 head(결론) 과 match되면 다음에 rule의 body(전제)가 만족되어야 한다.
그때 rule의 body가 만족되는 subgoal의 새로운 집합을 구성한다. 이것은
goal tree를 만든다
4. goal
tree의 extremities (leaves)각자에 대해 matching fact가 발견되면
비로소 goal이 만족되는 것이다
DOMAINS
name,thing = symbol
PREDICATES
likes(name, thing)
reads(name)
is_inquisitive(name)
CLAUSES
likes(john,wine):-!. /* subgoal likes(X,wine)
와 match, X는 john과 bind*/
likes(lance,skiing):-!.
likes(lance,books):-!.
likes(lance,films):-!.
likes(Z,books):- reads(Z), is_inquisitive(Z).
/* likes(X,books)와
match,변수 Z는 X와 match 가능, unify . rule의 body를 만족시켜야...새로운
subgoal집합으로 tree구성*/
reads(john).
/* 새로운
subgoal tree를 만족시킴 */
is_inquisitive(john).
/* extremity 각자에 대한 matching fact */
GOAL
likes(X,wine), likes(X,books)
/* 2개의 subgoal로 구성되는 goal tree */
출력
X =
john
1 solution
The Four Basic Principles of Backtracking
In this example, the goal tree shows that two subgoals must be
satisfied. To do so, Visual Prolog
follows the first basic principle of backtracking:
Subgoals must be
satisfied in order, from top to bottom.
|
Visual
Prolog determines which subgoal it will use when trying to satisfy the
clause according to the second basic principle of backtracking:
|
Predicate clauses
are tested in the order they appear in the program, from top to bottom.
|
When executing Program 4, Visual Prolog finds a matching clause with
the first fact defining the likes predicate. Take a look at the
goal tree now.
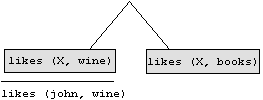
The subgoal likes(X, wine)
matches the fact likes(john,
wine) and binds X
to the value john. Visual Prolog tries to satisfy the next
subgoal to the right.
The call to the second subgoal begins a
completely new search with the binding X
= john. The first clause
likes(john, wine)
does not match the subgoal
likes(X, books)
since wine
is not the same as books. Visual Prolog must therefore try the next
clause, but lance does not match the
value X (because, in this case, X is bound to john), so the search continues to the third clause defining the
predicate likes:
likes(Z, books):- reads(Z),
is_inquisitive(Z).
The argument Z
is a variable, so it is able to match with X.
The second arguments agree, so the call matches the head of the rule. When X matches Z, the arguments are unified.
With the arguments unified, Visual Prolog
will equate the value X has (which is
john) with the variable Z. Because of this, now the variable Z also has the value john.
The subgoal now matches the left side (head) of
a rule. Continued searching is determined by the third basic principle of
backtracking:
When a subgoal matches the head of a rule, the
body of that rule must be satisfied next. The body of the rule then constitutes
a new set of subgoals to be satisfied.
|
This yields the following goal tree:
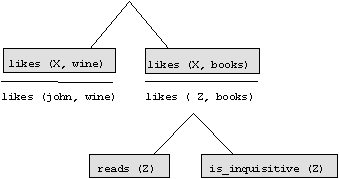
The goal tree now
includes the subgoals
reads(Z) and is_inquisitive(Z)
where Z is bound to the value john. Visual
Prolog will now search for facts that match both subgoals. This is the
resulting final goal tree:
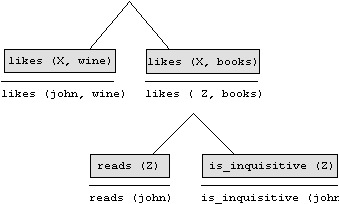
According to the fourth basic principle of
backtracking:
A goal has been satisfied when a matching fact
is found for each of the extremities (leaves) of the goal tree.
|
So now the initial goal is satisfied.
Visual Prolog
uses the result of the search procedure in different ways, depending on how the
search was initiated. If the goal is a call from a subgoal in the body of a
rule, Visual Prolog attempts to
satisfy the next subgoal in the rule after the call has returned. If the goal
is a query from the user, Visual Prolog
replies directly:
X=john
1 Solution
As you saw in Program 4, having once satisfied
an external goal, Visual Prolog
backtracks to find all alternate solutions. It also backtracks if a subgoal
fails, hoping to re-satisfy a previous subgoal in such a way that the failed
subgoal is satisfied by other clauses.
To fulfill a subgoal, Visual Prolog begins a search with the first clause that defines
the predicate. One of two things can then happen:
It finds a matching
clause, in which case the following occurs:
If there is another clause that can possibly re-satisfy the subgoal,
Visual Prolog places a pointer (to
indicate a backtracking point) next to the matching clause.
All free variables in the subgoal that match values in the clause
are bound to the corresponding values.
If the matching clause is the head of a rule, that rule's body is
then evaluated; the body's subgoals must succeed for the call to succeed.
It can't find a
matching clause, so the goal fails. Visual
Prolog backtracks as it attempts to re-satisfy a previous subgoal. When
processing reaches the last backtracking point, Visual Prolog frees all variables that had been assigned new
values since the backtracking point was set, then attempts to re-satisfy the
original call.
Visual Prolog
begins a search from the top of the program. When it backtracks to a call, the
new search begins from the last backtracking point set. If the search is
unsuccessful, it backtracks again. If backtracking exhausts all clauses for all
subgoals, the goal fails.
Backtracking
Here is another, slightly more complex, example,
illustrating how backtracking takes place in Prolog.
/* Program ch04e05.pro */
PREDICATES
nondeterm type(symbol,
symbol)
nondeterm
is_a(symbol, symbol)
lives(symbol,
symbol)
nondeterm
can_swim(symbol)
CLAUSES
type(ungulate,animal). /* type(X,animal) 과 match, X는
ungulate에 bind */
type(fish,animal). /*
backtracking point, redo : X는 fish에 bind */
is_a(zebra,ungulate).
/* is_a(Y,X) 와 match, Y는 zebra와 bind */
is_a(herring,fish).
/* redo : is_a(Y,ungulate) 와 no match (fail),
Y는 herring에 bind*/
is_a(shark,fish).
/* " */ /* backtracking point, redo : Y는 shark에 bind */
lives(zebra,on_land).
lives(frog,on_land).
lives(frog,in_water).
lives(shark,in_water).
can_swim(Y):-
/*
head of rule match */
type(X,animal),
/* call */
is_a(Y,X),
/* is_a(Y,ungulate)를 call, is_a(Y,fish)를 call */
lives(Y,in_water).
/* lives(zebre,in_water)를 call , no match (fail),
lives(herring,in_water)를 call, no match,
lives(shark,in_water)를
call, match */
GOAL
can_swim(What),
write("A ",What,"
can swim\n").
출력
A shark
can swim
What
= shark
1 solution
This example program uses an internal goal to illustrate how
backtracking works. When the program is compiled and run, Visual Prolog will automatically begin
executing the goal, attempting to satisfy all the subgoals in the goal section.
Visual Prolog calls the can_swim
predicate with a free variable, What.
In trying to solve this call, Visual Prolog
searches the program looking for a match. It finds a match with the clause
defining can_swim, and the variable What
is unified with the variable Y.
Next, Visual Prolog attempts to satisfy the body
of the rule. In doing so, Visual Prolog
calls the first subgoal in the body of the rule, type(X, animal),
and searches for a match to this call. It finds a match with the first fact
defining the type relationship.
At this point, X is bound to ungulate. Since there is more than one possible solution, Visual Prolog sets a backtracking point at
the fact type(ungulate,
animal).
With X bound to ungulate, Visual Prolog
makes a call to the second subgoal in the rule (is_a(Y, ungulate)), and again searches for a match. It finds one with the first fact, is_a(zebra, ungulate). Y is bound to zebra and Prolog sets a backtracking
point at is_a(zebra,
ungulate).
Now, with X bound to ungulate and Y bound to zebra, Prolog tries to satisfy the last
subgoal, lives(zebra,
in_water). Prolog tries each lives clause, but there
is no lives(zebra,
in_water) clause in the program, so the call fails and
Prolog begins to backtrack in search of another solution.
When Visual Prolog backtracks, processing returns
to the last point where a backtracking point was placed. In this case, the last
backtracking point was placed at the second subgoal in the rule, on the fact is_a(zebra, ungulate).
When Visual Prolog reaches a backtracking point,
it frees the variables that were assigned new values after the last
backtracking point and attempts to find another solution to the call it made at
that time. In this case, the call was is_a(Y, ungulate).
Visual Prolog continues down into the
clauses in search of another clause that will match with this one, starting
from the point where it previously left off. Since there are no other clauses
in the program that can match this one, the call fails and Visual Prolog backtracks again in an
attempt to solve the original goal.
From this position,
the last backtracking point was set at type(ungulate, animal).
Visual Prolog frees the variables set in
the original call and tries to find another solution to the call type(X, animal).
The search begins after the backtracking point. Visual Prolog finds a match with the next type fact in the program (type(fish, animal)); X is bound to fish, and a new backtracking point is
set at that fact.
Visual Prolog now moves down to the next
subgoal in the rule; since this is a new call, the search begins at the top of
the program with is_a(Y,
fish).
Visual Prolog finds a match to this call
and Y is bound to herring.
Since Y is now bound to herring, the next subgoal called is lives(herring, in_water). Again, this is a new call, and the search begins from the top of
the program.
Visual Prolog tries each lives
fact, but fails to find a match and the subgoal fails.
Visual Prolog now returns to the last
backtracking point, is_a(herring,
fish).
The variables that
were bound by this matching are now freed. Starting at the point where it last
left off, Visual Prolog now searches
for a new solution to the call
is_a(Y, fish).
Visual Prolog finds a match with the next is_a
clause, and Y becomes bound to the
symbol shark.
Visual Prolog tries the last subgoal again,
with the variable Y bound to shark. It calls lives(shark, in_water); the search begins at the top of the program, since this is a new
call. It finds a match and the last subgoal to the rule succeeds.
At this point, the
body of the can_swim(Y) rule is satisfied. Visual Prolog
returns Y to the call can_swim(What).
Since What is bound to Y, and Y is bound to shark, What is now bound to shark in the goal.
Visual Prolog continues processing where it
left off in the goal section, and
calls the second subgoal in the goal.
Visual Prolog completes the program by
outputting
A shark can swim.
and the program terminates successfully.
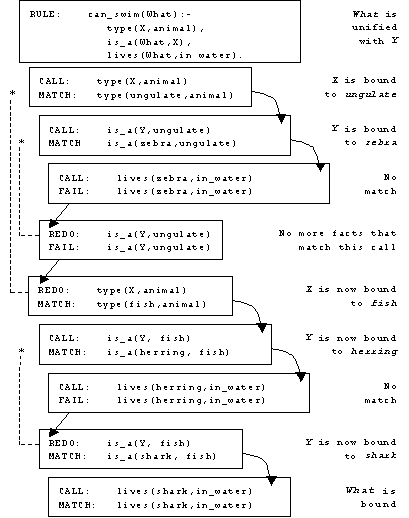
Figure 4.1: How the can_swim Program
Works
Prolog's built-in backtracking mechanism can result in unnecessary
searching; because of this, inefficiencies can arise. For instance, there may
be times when you want to find unique solutions to a given question. In other
cases, it may be necessary to force Visual
Prolog to continue looking for additional solutions even though a
particular goal has been satisfied. In cases such as these, you must control
the backtracking process. In this section, we'll show you some techniques you
can use to control Visual Prolog's
search for the solutions to your goals.
Visual Prolog
provides two tools that allow you to control the backtracking mechanism: the fail
predicate, which is used to force
backtracking, and the cut (signified by !), which is used
to prevent backtracking.
Visual Prolog begins
backtracking when a call fails. In certain situations, it's necessary to force
backtracking in order to find alternate solutions. Visual Prolog provides a special predicate, fail, to force failure
and thereby encourage backtracking. The effect of the fail predicate
corresponds to the effect of the comparison 2 = 3 or any
other impossible subgoal. Program 6 illustrates the use of this special
predicate.
/* Program ch04e06.pro */
backtracking
mechanism은 불필요한 탐색을 하여 비능률을 초래할수 있다. 즉 단 하나의
(unique)답만을 찾는 경우 라든가 반대로 여러개의 답을 찾기위해 추가적인
탐색을 강요하는 경우가 있다. 이를 위해서 backtracking process를
제어할 필요가 있다. 이를 위해서는 2가지 방법을 사용한다.
1. backtracking을
강요 (force)하는 fail predicate.
2. backtracking을
방지 (prevent)하는 cut ( ! ).
하나의
call이 실패하면 backtracking하게 되는데 어떤 경우에는 부가적인 답을
찾기위해서 backtracking을 강제할 경우가 있다.
fail 문장은 failure를 강제하고 그럼으로써 backtracking을
야기한다. fail 문장의 효과는 2 = 3 과 같은 impossible
subgoal 의 효과와 같다. 다음은 fail 문장의 예이다.
DOMAINS
name = symbol
PREDICATES
nondeterm father(name,
name)
everybody
CLAUSES
father(leonard,katherine).
father(carl,jason).
father(carl,marilyn).
everybody:- /* father(X,Y) 의 또다른 답을 위해
backtracking */
father(X,Y),
write(X," is
",Y,"'s father\n"),
fail.
/* 결코 만족될수
없는 항상 fail, backtracking 강요*/
everybody. /*
fail 이 없다면 backtrack할 이유가 없다 */
/*
fail 은 last call까지 backtrack 한다 */
GOAL
everybody. /* father(X,
Y) 보다도 더 명확한 답을 보여준다*/
/*
prolog에서 여러개의 답을 낼수 있도록 마지막 call까지 backtrack하게되는데
이러한 call을 non-deterministic call 이라
한다. 단지 하나의 답만을 낼수 있는 call을 deterministic
call이라 한다*/
출력
leonard
is katherine's father /*fail에 의해서 가능한
모든 답을 낸다*/
carl
is jason's father
carl
is marilyn's father
yes
Once an internal goal has completely succeeded,
there is nothing that tells Visual Prolog
to backtrack. Because of this, an internal call to father will come up with
only one solution. However, the predicate everybody in Program 6 uses fail
to force backtracking, and therefore finds all possible solutions.
The object of the predicate everybody is to produce a
cleaner response from program runs. Compare the answers to the two preceding
goals:
Goal father(X, Y).
X=leonard, Y=katherine
X=carl, Y=jason
X=carl, Y=marilyn
3 Solutions
and
Goal everybody.
leonard is katherine's father
carl is jason's father
carl is marilyn's father
yes
The predicate everybody uses
backtracking to generate more solutions for father(X, Y) by
forcing Prolog to backtrack through the body of the everybody rule:
father(X, Y), write(X," is
",Y,"'s father\n"), fail.
fail can never be
satisfied (it always fails), so Visual
Prolog is forced to backtrack. When backtracking takes place, Prolog
backtracks to the last call that can produce multiple solutions. Such
a call is labeled non-deterministic.
A
non-deterministic call contrasts with a call that can produce only one
solution, which is a deterministic call.
The write
predicate can't be re-satisfied (it can't offer new solutions), so Visual Prolog must backtrack again, this
time to the first subgoal in the rule.
Notice that it's useless to place a subgoal
after fail in the body of a rule. Since the predicate fail
always fails, there would be no way of reaching a subgoal located after fail.
Exercises
Load and run
Program 6 and evaluate the following goals:
a. father(X, Y).
b. everybody.
2. Edit the body of
the rule defining everybody so that the rule ends with the call to the write
predicate (delete the call to fail). Now compile and run the
program, giving everybody. as the goal. Why doesn't Visual
Prolog find all the solutions as it does with the query father(X, Y)?
3. Relocate the
call to fail at the end of the everybody rule. Again, give the
query everybody as the goal. Why are the solutions to everybody terminated by
no? For a clue, append everybody. as a second clause to the definition of predicate everybody
and re-evaluate the goal.
Visual Prolog contains the
cut, which is used to
prevent backtracking; it's written as an exclamation mark (!). The effect of
the cut is simple: It is impossible to backtrack across a cut.
You place the cut in your program the same way
you place a subgoal in the body of a rule. When processing comes across the
cut, the call to cut immediately succeeds, and the next subgoal (if there is
one) is called. Once a cut has been passed, it is not possible to backtrack to
subgoals placed before the cut in the clause being processed, and it is not
possible to backtrack to other predicates defining the predicate currently in
process (the predicate containing the cut).
There are two main uses of the cut:
When you know in advance that certain possibilities will never give
rise to meaningful solutions, it's a waste of time and storage space to look
for alternate solutions. If you use a cut in this situation, your resulting
program will run quicker and use less memory. This is called a green cut.
When the logic of a program demands the cut, to prevent
consideration of alternate subgoals. This is a red cut.
How to Use the Cut
In this section, we give examples that show how you can use the cut
in your programs. In these examples, we use several schematic Visual Prolog rules (r1, r2, and r3), which all describe the same
predicate r, plus several subgoals (a,
b, c, etc.).
Prevent Backtracking to a Previous Subgoal in a Rule
r1 :- a, b, !, c.
This is a way of telling Visual Prolog that you are satisfied with the first solution it
finds to the subgoals a and b. Although Visual Prolog is able to find multiple solutions to the call to c through backtracking, it is not
allowed to backtrack across the cut to find an alternate solution to the calls a or b.
It is also not allowed to backtrack to another clause that defines the
predicate r1.
As a concrete example, consider Program 7.
/* Program ch04e07.pro */
backtracking을
막기위해서 exclamation mark (!)를 사용하는 것을 cut 이라 한다. cut을 가로질러 backtrack하는
것은 불가능하다. rule의 body에 subgoal을 위치시키는 것과 같은 방식으로
cut을 위치시킨다. cut 으로의 호출은 즉시 성공하고 다음 subgoal이
호출된다. 일단 cut 이 지나가면 cut 이전의 subgoal로 backtrack하는
것은 불가능하다. 또한 cut을 포함한 predicate를 정의하고 있는 다른
predicate로의 backtrack도 불가능하다. cut 의 용도는 크게 2가지이다.
1. 의미있는
답이 나올 가능성이 전혀 없다는 것을 미리 알고 있을 때 다른 답을
구하는 것은 시간과 memory의 낭비이다. 이 상황에서 cut을 사용하면
프로그램은 더 빨리 실행되고 memory를 덜 사용한다. 이것을
green cut 이라 부른다
2. 프로그램의
logic이 cut을 요구할 때, 즉 추가의 subgoal 의 고려를 방지하기 위해서
사용한다. 이것을 red cut 이라 한다
r1 :- a, b, !, c.
위의
문장에서 subgoal a, b 에 대한 답이 구해진후에 c 에 대한 답이 backtrack에
의해 여러개 구해지더라도 call a, b 에 대한 추가적인 해를 구하기
위한 backtrack는 허용되지 않는다. 또한 predicate r1을 정의한 또다른
clause로의 backtrack도 허용되지 않는다.
PREDICATES
buy_car(symbol,symbol)
nondeterm car(symbol,symbol,integer)
colors(symbol,symbol)
CLAUSES
buy_car(Model,Color):-
car(Model,Color,Price),
/*first subgoal*/
colors(Color,sexy),!,
/*cut을 만나는 순간 bind되었던 변수값들 동결*/
Price > 25000.
/*
test succeed*/
car(maserati,green,25000).
car(corvette,black,24000). /* match,Color
는 black로 bind */
car(corvette,red,26000).
/*backtrack, match, Color는 red로
bind,
Price는 26000*/
car(porsche,red,24000).
colors(red,sexy).
/* sexy 가 메치됨*/
colors(black,mean). /* 선택된
차가 sexy color인지 테스트, fail*/
colors(green,preppy).
GOAL
buy_car(corvette,
Y).
/* 위에서 Price < 25000 이라면 test 는 fail, 앞쪽의
subgoal 로 backtrack 할수 없어 fjnal subgoal 인 Price 문제의 해결을 위한 방법은
없고 goal 은 failure 로 끝난다 */
출력
Y =
red
1 solution
In this example, the goal is to find a Corvette
with a sexy color and a price that's ostensibly affordable. The cut in the buy_car
rule means that, since there is only one Corvette with a sexy color in the
database, if its price is too high there's no need to search for another car.
Given the goal
buy_car(corvette, Y)
Visual Prolog calls car, the first subgoal to
the buy_car
predicate.
It makes a test on
the first car, the Maserati, which fails.
It then tests the
next car
clauses and finds a match, binding the variable Color with the value black.
It proceeds to the
next call and tests to see whether the car chosen has a sexy color. Black is
not a sexy color in the program, so the test fails.
Visual Prolog backtracks to the call to car
and once again looks for a Corvette to meet the criteria.
It finds a match
and again tests the color. This time the color is sexy, and Visual Prolog proceeds to the next subgoal
in the rule: the cut. The cut immediately succeeds and effectively
"freezes into place" the variable bindings previously made in this
clause.
Visual Prolog now proceeds to the next (and
final) subgoal in the rule: the comparison
Price < 25000.
This test fails,
and Visual Prolog attempts to
backtrack in order to find another car to test. Since the cut prevents
backtracking, there is no other way to solve the final subgoal, and the goal
terminates in failure.
Prevent Backtracking to the Next Clause
The cut can be used as a way to tell Visual Prolog that it has chosen the
correct clause for a particular predicate. For example, consider the following
code:
r(1):- ! , a , b , c.
r(2):- ! , d.
r(3):- ! , c.
r(_):- write("This is a catchall
clause.").
Using the cut makes the predicate r
deterministic. Here, Visual Prolog
calls r with a single integer argument. Assume that the call is r(1).
Visual Prolog searches the program,
looking for a match to the call; it finds one with the first clause defining r.
Since there is more than one possible solution to the call, Visual Prolog places a backtracking point
next to this clause.
Now the rule fires and Visual Prolog begins to process the body of the rule. The first
thing that happens is that it passes the cut; doing so eliminates the
possibility of backtracking to another r clause. This eliminates
backtracking points, increasing the run-time efficiency. It also ensures that
the error-trapping clause is executed only if none of the other conditions
match the call to r.
Note that this type of structure is much like a
"case" structure written in other programming languages. Also notice
that the test condition is coded into the head of the rules. You could just as
easily write the clauses like this:
r(X) :- X = 1 , ! , a , b , c.
r(X) :- X = 2 , ! , d.
r(X) :- X = 3 , ! , c.
r(_) :- write("This is a catchall
clause.").
However, you should place the testing condition
in the head of the rule as much as possible, as doing this adds efficiency to
the program and makes for easier reading.
As another example, consider the following
program. Run this program and give the query friend(bill, Who) as the goal.
/* Program ch04e08.pro */
r(1)
:- !, a, b, c.
r(2)
:- !, d.
r(3)
:- !, c.
r(_)
:- write ("This is a catchall clause.").
cut을
사용하여 predicate r을 deterministic하게 만든다. r(1), r(2), r(3),
r(_) 중에서 하나라도 body of rule이 성공하면 cut은
backtracking point를 제거하여 또다른 r clause로의 backtracking 가능성을
없애서 단 하나의 r만 수행되게 한다. 다른 r 의 어떤 condition도
match가 되지 않을 때 마지막의 error message 문장이 수행된다
PREDICATES
friend(symbol,symbol)
girl(symbol)
likes(symbol,symbol)
CLAUSES
friend(bill,jane):-
girl(jane),
likes(bill,jane),!.
friend(bill,jim):-
likes(jim,baseball),!.
/* cut이 없다면 답은 2개 */
friend(bill,sue):-
girl(sue).
girl(mary).
girl(jane).
girl(sue).
likes(jim,baseball).
likes(bill,sue).
GOAL
friend(bill,Who).
출력
Who
= jim
1 solution
/* non-deterministic
clause를 body of rule 에 cut을 삽입함으로써 deterministic
clause로 만들수 있다. 위에서 friend predicate는 하나를 리턴하여
오직 하나의 solution만을 가지므로 deterministic 하다.*/
Without cuts in the program, Visual Prolog would come up with two
solutions: Bill is a friend of both Jane and Sue. However, the cut in the first
clause defining friend tells Visual Prolog
that, if this clause is satisfied, it has found a friend of Bill and there's no
need to continue searching for more friends. A cut of this type says, in
effect, that you are satisfied with the solution found and that there is no
reason to continue searching for another friend.
Backtracking can take place inside the clauses,
in an attempt to satisfy the call, but once a solution is found, Visual Prolog passes a cut. The friend
clauses, written as such, will return one and only one friend of Bill's (given
that a friend can be found).
Determinism and the Cut
If the friend predicate (defined in the previous program) were coded
without the cuts, it would be a non-deterministic predicate (one capable of
generating multiple solutions through backtracking). In many implementations of
Prolog, programmers must take special care with non-deterministic clauses
because of the attendant demands made on memory resources at run time. However,
Visual Prolog makes internal checks
for non-deterministic clauses, reducing the burden on you, the programmer.
However, for debugging (and other) purposes, it
can still be necessary for you to intercede; the check_determ
compiler directive is provided for this reason. If check_determ is
inserted at the very beginning of a program, Visual
Prolog will display a warning if it encounters any non-deterministic
clauses during compilation.
You can make non-deterministic clauses into
deterministic clauses by inserting cuts into the body of the rules defining the
predicate. For example, placing cuts in the clauses defining the friend
predicate causes that predicate to be deterministic because, with the cuts in
place, a call to friend can return one, and only one, solution.
The not Predicate
This program demonstrates how you can use the not predicate to identify
an honor student: one whose grade point average (GPA) is at least 3.5 and who
is not on probation.
/* Program ch04e10.pro */
not
은 subgoal이 true라고 증명될수 없을 때 성공한다
DOMAINS
name = symbol
gpa = real
PREDICATES
nondeterm honor_student(name)
nondeterm student(name,
gpa)
probation(name)
CLAUSES
honor_student(Name):-
student(Name,
GPA),
GPA>=3.5,
not(probation(Name)).
student("Betty
Blue", 3.5).
student("David Smith",
2.0).
student("John Johnson", 3.7).
probation("Betty
Blue").
probation("David Smith").
GOAL
honor_student(X).
출력
X =
John Johnson
1 solution
/* probation
: 보호 관찰중인 상태 */
There is one thing to note when using not:
The
not predicate succeeds when the subgoal can't be proven true. This results in a
situation that prevents unbound variables from being bound within a not.
When a subgoal with free variables is called from within not, Visual Prolog will return the error message
Free
variables not allowed in 'not' or 'retractall'. This
happens because, for Prolog to bind the free variables in a subgoal, that
subgoal must unify with some other clause and the subgoal must succeed. The
correct way to handle unbound variables within a not subgoal is with
anonymous variables.
Here are some examples of correct clauses and
incorrect clauses.
likes(bill, Anyone):- /* 'Anyone' is an output argument
*/
likes(sue, Anyone),
not(hates(bill, Anyone).
In this example, Anyone is bound by likes(sue,
Anyone) before Visual
Prolog finds out that hates(bill,
Anyone) is not true. This clause works just as it
should.
If you rewrite this so that it calls not
first, you will get an error message to the effect that free variables are not
allowed in not.
likes(bill, Anyone):- /*
This won't work right */
not(hates(bill, Anyone)),
likes(sue, Anyone).
Even if you correct this (by replacing Anyone in not(hates(bill, Anyone)) with an anonymous variable) so that the clause does not return the
error, it will still return the wrong result.
likes(bill, Anyone):- /*
This won't work right */
not(hates(bill, _)),
likes(sue, Anyone).
This clause states that Bill likes Anyone if nothing that Bill hates is
known and if Sue likes Anyone. The
original clause stated that Bill likes Anyone
if there is some Anyone that Sue
likes and that Bill does not hate.
Example
Always be sure that you think twice when using
the not
predicate. Incorrect use will result in an error message or errors in your
program's logic. The following is an example of the proper way to use the not
predicate.
/* Program ch04e11.pro */
not
은 부적절하게 사용시 error message를 내거나 logic상의 error를 발생시킨다.
다음은 not 의 적절한 사용예이다.
PREDICATES
nondeterm likes_shopping(symbol)
nondeterm has_credit_card(symbol,symbol)
bottomed_out(symbol,symbol)
CLAUSES
likes_shopping(Who):-
has_credit_card(Who,Card),
not(bottomed_out(Who,Card)),
write(Who,"
can shop with the ",Card, " credit card.\n").
has_credit_card(chris,visa).
has_credit_card(chris,diners).
has_credit_card(joe,shell).
has_credit_card(sam,mastercard).
has_credit_card(sam,citibank).
bottomed_out(chris,diners).
bottomed_out(sam,mastercard).
bottomed_out(chris,visa).
GOAL
likes_shopping(Who).
출력
joe
can shop with the shell credit card.
Who
= joe
sam
can shop with the citibank credit card.
Who
= sam
2 solutions
Exercises
Suppose an average
taxpayer in the USA is a married US citizen with two children who earns no less
than $500 a month and no more than $2,000 per month. Define a special_taxpayer
predicate that, given the goal special_taxpayer(fred)., will succeed only if fred
fails one of the conditions for an average taxpayer. Use the cut to ensure that
there is no unnecessary backtracking.
Players in a
certain squash club are divided into three leagues, and players may only
challenge members in their own league or the league below (if there is one).
Write a Visual
Prolog program that will display all possible matches between club
players in the form:
tom versus bill
marjory versus annette
Use the cut to ensure, for example, that
tom versus bill
and
bill versus tom
are not both displayed.
This is an exercise
in backtracking, not a test of your ability to solve murder mysteries. Load and
run the following program, then enter the goal killer(X).
(Note:
Bert is guilty because he has a motive and is smeared in the same stuff as the
victim.)
/* Program ch04e12.pro */
다음은
backtracking 에 관한 연습이다.
Bert
는 motive(동기)를 가지고 있고 희생자와 같은 stuff (음식 또는 오물)로 smeared_in
(더럽혀졌기) 때문에 유죄다.
trace
DOMAINS
name,sex,occupation,object,vice,substance
= symbol
age=integer
PREDICATES
nondeterm person(name,
age, sex, occupation)
nondeterm
had_affair(name, name)
killed_with(name,
object)
killed(name)
nondeterm killer(name)
motive(vice)
smeared_in(name,
substance)
owns(name,
object)
nondeterm
operates_identically(object, object)
nondeterm
owns_probably(name, object)
nondeterm
suspect(name)
/* *
* 살해 사건과 관련된 사실 * * */
CLAUSES
person(bert,55,m,carpenter).
person(allan,25,m,football_player).
person(allan,25,m,butcher).
person(john,25,m,pickpocket).
had_affair(barbara,john).
had_affair(barbara,bert).
had_affair(susan,john).
killed_with(susan,club).
killed(susan).
motive(money).
motive(jealousy).
motive(righteousness).
smeared_in(bert,
blood).
smeared_in(susan, blood).
smeared_in(allan,
mud).
smeared_in(john, chocolate).
smeared_in(barbara,chocolate).
owns(bert,wooden_leg).
owns(john,pistol).
/* *
* 배경 지식 * * */
operates_identically(wooden_leg,
club).
operates_identically(bar, club).
operates_identically(pair_of_scissors,
knife).
operates_identically(football_boot, club).
owns_probably(X,football_boot):-
person(X,_,_,football_player).
owns_probably(X,pair_of_scissors):-
person(X,_,_,hairdresser).
owns_probably(X,Object):-
owns(X,Object).
/* *
* * * * * * * * * * * * * * * * * * * * *
* Susan 이 살해될
만한 무기를 가진 사람을 의심 *
* * * * * * * * * * * * * * * * * * * * * * */
suspect(X):-
killed_with(susan,Weapon)
,
operates_identically(Object,Weapon)
,
owns_probably(X,Object).
/* *
* * * * * * * * * * * * * * * * * * * * * * * *
* Susan
과 관계를 가진 남자를 의심 *
* * * *
* * * * * * * * * * * * * * * * * * * * * */
suspect(X):-
motive(jealousy),
person(X,_,m,_),
had_affair(susan,X).
/* *
* ** *
* * *
* * *
* * *
* * * * * * * * * * * * * * * *
* Susan을 아는 어떤
사람과 관계를 가진 여성을 의심 *
* * * * *
* * * * * * * * * * ** *
* * *
* * *
* * * * * * */
suspect(X):-
motive(jealousy),
person(X,_,f,_),
had_affair(X,Man),
had_affair(susan,Man).
/* *
* * * * * * * * * * * * * * * * * * * * * * * * *
* 돈을
노린 소매치기를 의심 *
* * *
* * * * * * * * * * * * * * * * * * * * * * * */
suspect(X):-
motive(money),
person(X,_,_,pickpocket).
killer(Killer):-
person(Killer,_,_,_),
killed(Killed),
Killed <>
Killer, /* It is not a suicide */
suspect(Killer),
smeared_in(Killer,Goo),
smeared_in(Killed,Goo).
GOAL
killer(X).
출력
X =
bert
1 solution